GLB and USD
Textured meshes and structured scenes for 3D tools and simulation workflows.
 API docs ↗
The Gizmo API is Antim Labs’ asset generation API. Turn text and reference images into 3D objects for robotics and simulation—from everyday tools to moving mechanisms. Generate individual assets or batches, with materials, joints, and collision geometry for your task.
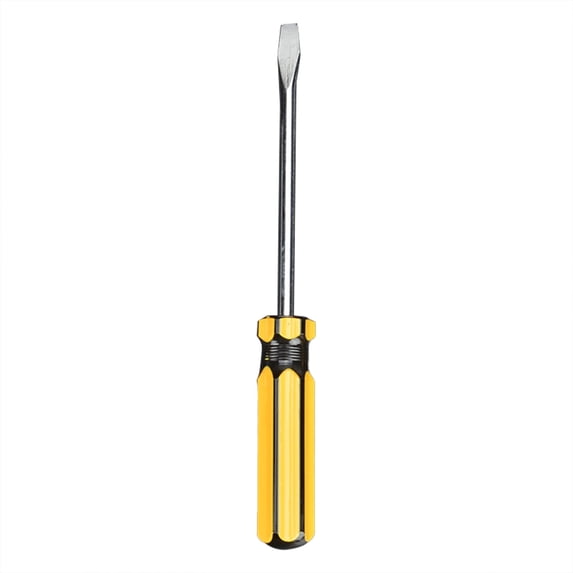
Recreate this flathead screwdriver with its steel shaft and yellow and black handle. Include collision geometry so a gripper can pick it up by the handle.
Example prompt for this asset.One grasp in Isaac Sim, shown as a visual model and as simulated contact geometry.
Scripted gripper motion, contact-driven asset motion.
See how the collision shapes support grasping, preserve openings, and move with articulated parts. Captured in Isaac Sim.
“Pick up the screwdriver by its handle.”
The gripper lifts, holds, and places the tool using its exported collision geometry.
“Insert a probe into the mug.”
The collision pieces follow the walls, leaving room for the gripper-held probe.
The same probe and gripper path meet a solid collision surface across the opening when the mug uses one outer hull.
“Grasp the handle and open the door.”
The door’s collision geometry follows its hinge while the oven body stays fixed.
This scene corrects the exported hinge position. The asset’s collision meshes are retained.
Physics demonstrations with scripted grippers. Collision views show the shapes used by PhysX; these are not learned robot policies.
Specify interactions in the APISend a text prompt, optional reference images, and the interactions the asset needs to support.
Follow the job until your asset is ready.
Download a supported format to import into your 3D tool or simulator.
Textured meshes and structured scenes for 3D tools and simulation workflows.
Per-body convex hulls, with hybrid convex and signed-distance-field geometry where supported.
USDZ, MJCF for MuJoCo, and SDF for Gazebo, depending on the asset and enabled release.
Need a custom format, collision setup, or simulator integration? Tell us what you need to generate and where it needs to run.